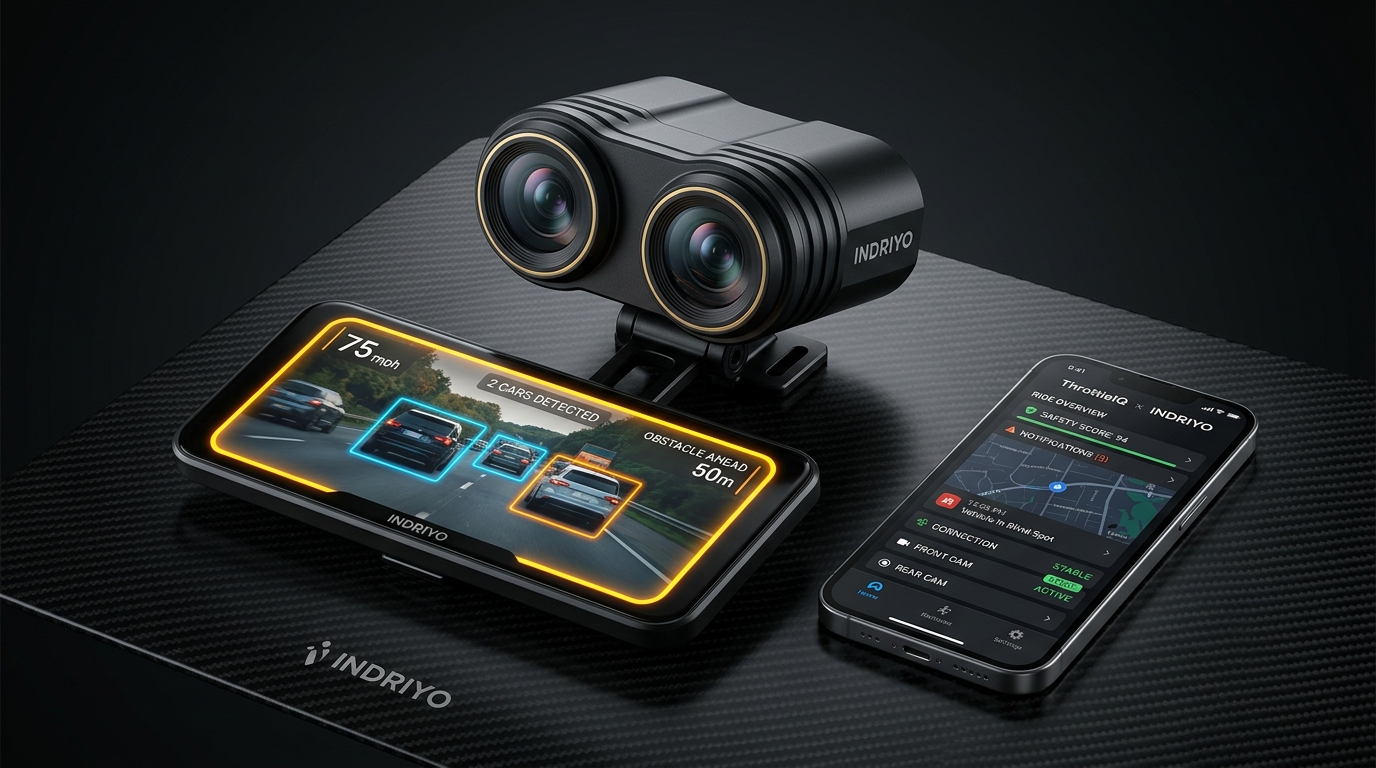
Eliminate blind spots and rear-end collisions with intelligent edge computer vision. Converts discreet tail cameras into an active, predictive safety layer with intuitive peripheral mirror alerts and real-time Time-to-Collision vectoring.
Experience how Indriyo tracks approaching vehicles, detects blind spot occupancy, and triggers peripheral amber and red warnings in real time.
Bridging the white space between screenless radar and dumb display dashcams.
Seamlessly monitors vehicles lingering in 120°–165° left and right rear quadrants. Triggers an immediate solid amber peripheral border so you know a vehicle is there without breaking head posture.
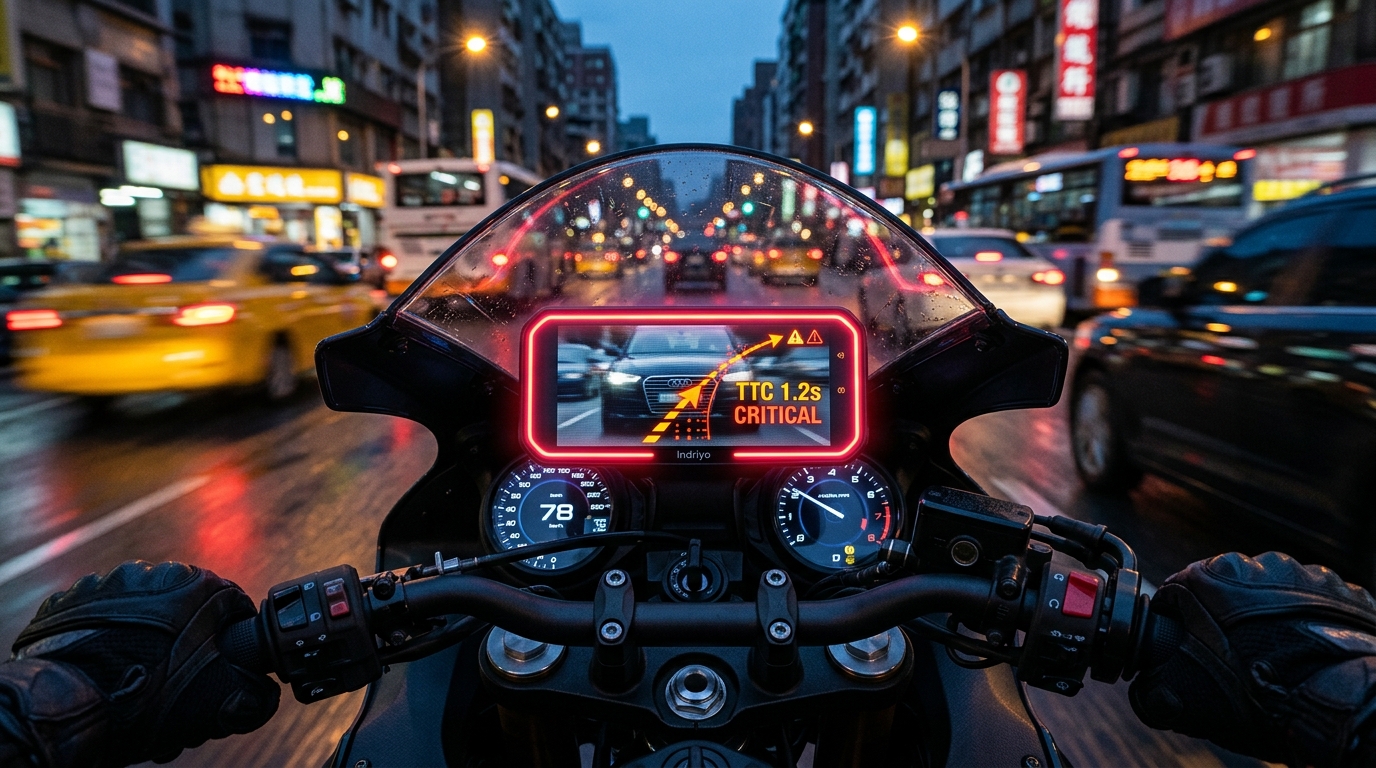
Uses Optical Expansion (Tau Theory) and relative velocity vectoring. Differentiates between a car pacing safely behind and a high-speed vehicle on a collision course (< 1.8s TTC).
Connects to your bike speed via OBD-II, GPS, or ThrottleIQ middleware. Scales sensitivity dynamically: stopped at a red light, approaching traffic triggers alerts from further away!
The human peripheral eye is highly sensitive to color strobes. Solid Amber draws gentle attention; rapidly flashing Crimson Red instantly triggers evasive action before a rear collision occurs.
No bulky 360° dome cameras or awkward radar boxes. Dual waterproof miniature optical lenses tuck invisibly beneath the pillion seat or license plate bracket.
Zero extra compute cost! Use your mounted phone as the AI brain via our drop-in Flutter module. Your phone ingests the ESP32 Wi-Fi feed, runs YOLO inference, and provides helmet audio warnings.
See why Indriyo is the only system offering both active visual verification and edge predictive intelligence.
| Feature / Metric | Indriyo (ইন্দ্রিয়) | Ride Vision 2 | Garmin Varia Radar | Chigee AIO-5 Smart Dash |
|---|---|---|---|---|
| Architecture | Dual AI Vision + Screen | Screenless Mirror LEDs | Radar Box (LED Blips) | CarPlay Screen (Dumb Cam) |
| Visual Feed ("Trust but Verify") | YES (Live Digital Mirror) | NO (No Display) | NO (No Video) | YES (Video Only) |
| Object Classification | YES (Car, Bike, Bus, Truck) | YES (AI Vision) | NO (Mass Only) | NO / Basic |
| Time-to-Collision (TTC) Vectoring | YES (Optical Tau + Speed) | YES (Proprietary) | Basic Proximity Radar | NO (Proximity Only) |
| Tail Aesthetic Footprint | Stealth Mini Dual Lenses | Bulky Front/Rear Pods | Bulky Radar Brick | Standard Dashcam |
| Bangladesh DIY Cost | < ৳3,000 BDT | ৳50,000+ (Imported) | ৳30,000+ (Imported) | ৳45,000+ (Imported) |
100% off-the-shelf components sourced locally from TechShopBD, BDTronics, and Daraz.
Protected from alternator voltage spikes, engine vibration, and battery parasitic drain.
Factory buck converters often ship set to 10V–12V. Turn the brass adjustment screw counter-clockwise until your multimeter reads exactly 5.1V before plugging in the ESP32s!
Solder one 1000µF 16V electrolytic capacitor directly across the 5V and GND pins of each ESP32 board to absorb Wi-Fi transmission spikes and stop reboots.
Motorcycle engine RPM vibrations can drift adjustment screws. Add a drop of clear nail polish or silicone adhesive to lock the screw head permanently in place.
Free, open-source 3D printable meshes, lightweight INT8 models, and real road validation data.
Aerodynamic motorcycle tail pod with 15° outward splay for dual ESP32-CAMs, rain lens visors, cable relief canal, and M4 mounting brackets.
Anti-glare sun visor cradle for 5" display/phone with 28mm glare hood, bottom USB cable pass-through, and dual 22mm/28mm bar clamps.
Stress-tested against real motorcycle rear dashcam footage in daytime traffic and night rain. Sub-2ms edge latency with 100% frame throughput.
Optimized YOLOv8n object detection engine quantized for mobile CPUs & edge NPUs. Slices latency to ~1.7ms per frame for instantaneous TTC warnings.
Promotional renders and Cockpit UI captures for the Indriyo launch campaign.